ELEN 323: Feedback control systems
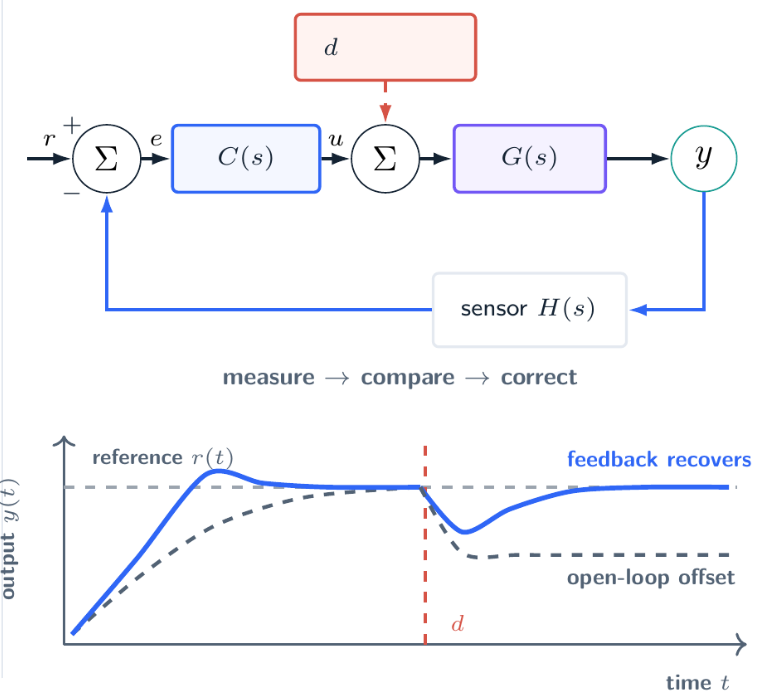
Teacher: Dr. Muhammad Bakr Abdelghany
Institution: Khalifa University of Science and Technology, Abu Dhabi, United Arab Emirates
Term: Fall 2026 · 4 credit hours
Office hours: Monday and Wednesday, 3:00–4:00 p.m., Room 3215
Course description
Students model systems with ordinary differential equations and transfer functions, assess performance and error, establish stability, and design controllers using root locus and frequency response. The course concludes with an introduction to state-space modelling, stability, and state-feedback design.
Syllabus
System modelling and transfer functions for linear time-invariant systems; transient and steady-state performance analysis; stability analysis using Routh–Hurwitz methods and root locus; frequency-response analysis using Bode and Nyquist methods; lead, lag, lag-lead, and PID controller design; introductory state-space modelling, stability analysis, and state-feedback design.
Prerequisites
ECCE 302 or ELEN 302 (Signals and Systems).
Official Khalifa University course catalog: ELEN 323 Feedback Control Systems.
Teaching format
Two 75-minute lectures are scheduled each week. Tutorials, problem solving, coursework, and simulation reinforce the theoretical material. Exact assessment and meeting dates follow the official academic calendar and instructor announcements.
Learning outcomes
Model different types of linear time-invariant systems. Design lead, lag, and PID controllers. Analyse the stability and performance of linear time-invariant systems. Design compensators using the root-locus method. Use MATLAB and Simulink to analyse system stability and controller designs.
Weekly teaching plan
| Week | Theory | Milestone |
|---|---|---|
| 1 | Introduction: the control problem, terminology, and motivation for feedback | Orientation |
| 2 | Dynamics of translational and rotational mechanical systems | – |
| 3 | Transfer functions of electrical and electronic circuits | – |
| 4 | Modelling electromechanical systems | – |
| 5 | Performance analysis of linear time-invariant systems | – |
| 6 | Routh–Hurwitz stability, root-locus construction, and MATLAB | – |
| 7 | Root-locus construction techniques and design method | Guided preview |
| 8 | Semester examination | Semester exam |
| 9 | Root-locus controller design, Bode plots, and LTI stability analysis | – |
| 10 | Lead and lag compensator design | – |
| 11 | Lag-lead compensation, PID controller design, and tuning | Guided preview |
| 12 | State-variable models, transfer-function conversions, and controllable and observable canonical forms | Assignment |
| 13 | Stability analysis of state-space models | – |
| 14 | State-space controller design | – |
| 15 | Revision and cumulative synthesis | Revision |
| 16 | Final examination period | Final exam |
Lecture slides
Course resources
Software. MATLAB with Control System Toolbox and Simulink.
Main reference
[1] R. C. Dorf and R. H. Bishop, Modern Control Systems, 14th ed., Pearson, 2021. ISBN-13: 978-1292422374.